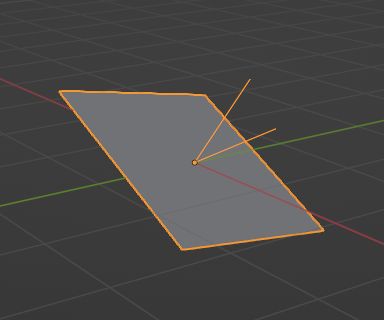
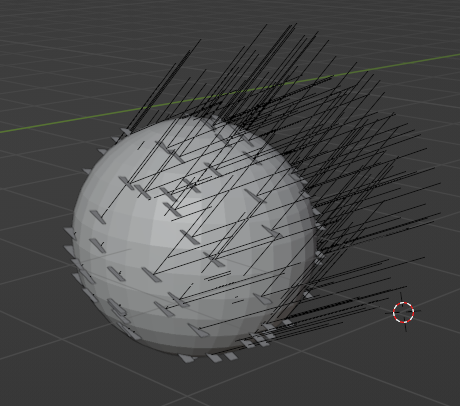
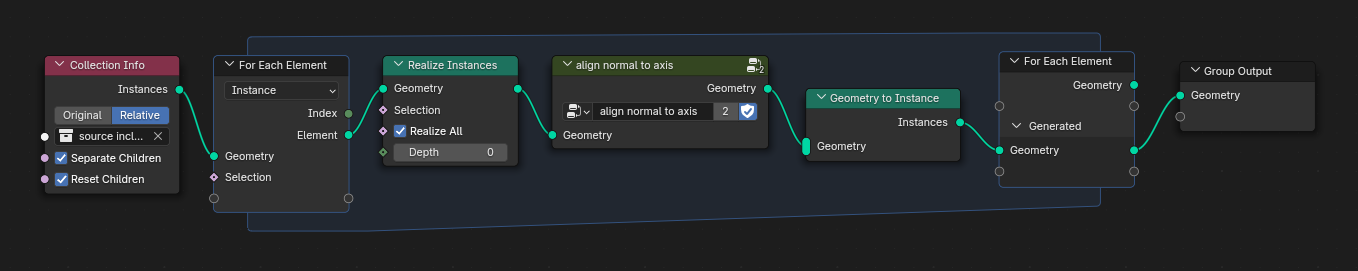
I have managed to find the face normal vector and position a mesh line primitive to visualize the face normal.
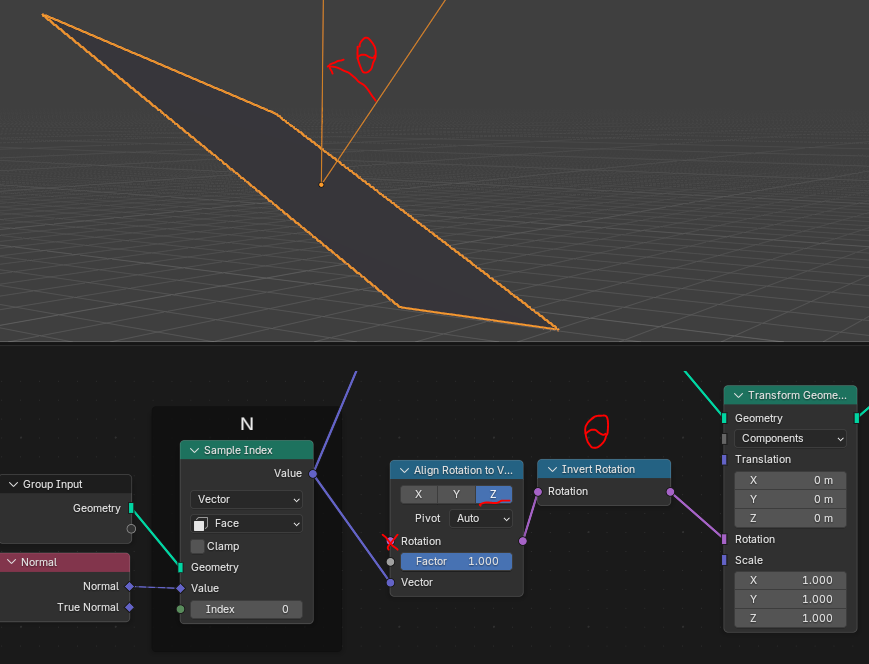
I need to now calculate the difference between the face normal and world Z so I can rotate the face so its normal points up in world z and then I want to instance the object on points created by Distribute Points On Faces on another object.
It works when there is only 1 object in the source include collection, but as I add more objects to the source, the rotation fix doesn’t get applied to them. How to fix the rotation on each thing in the collection instead of needing to put a Geometry Node modifier on each individual object?
You can try:
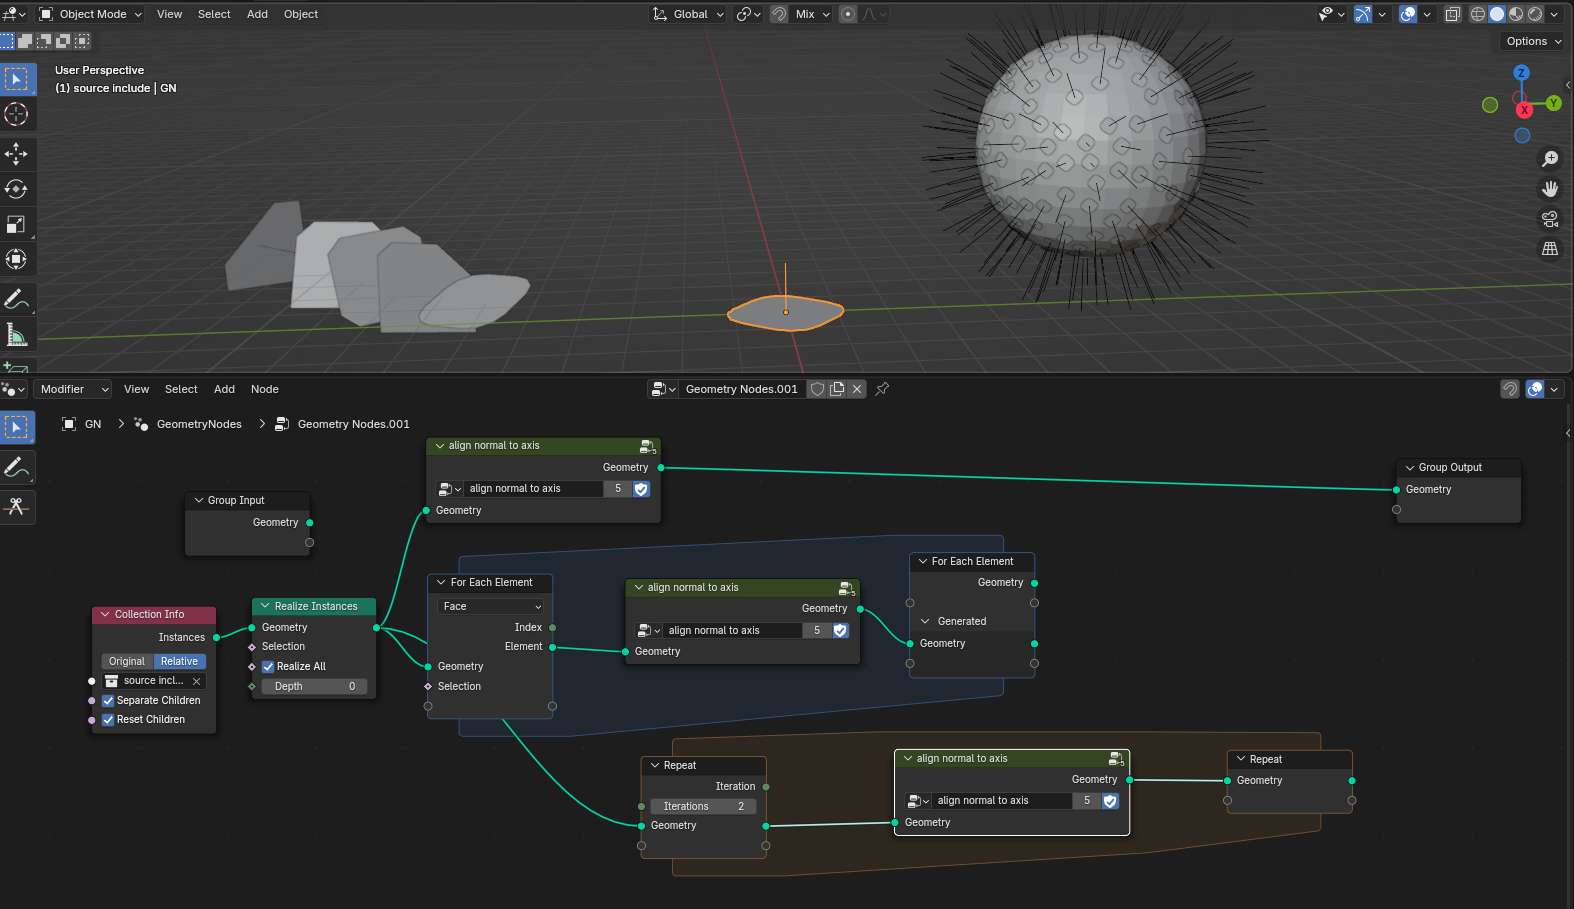
Input Instance in For Each node > set For Each: Instance > Realize Instances > rotate the face (apply you “align” node group) > Geometry to Instance > go to “For Each” exit.
The lower “For Each” geometry output should contain a collection of rotated instances, that you should be able to use as usual in Instance on Point.